
Autonomy architecture
Connect perception, world state, planning and control across humanoid robots and quadruped robot dogs, with explicit uncertainty and recovery.
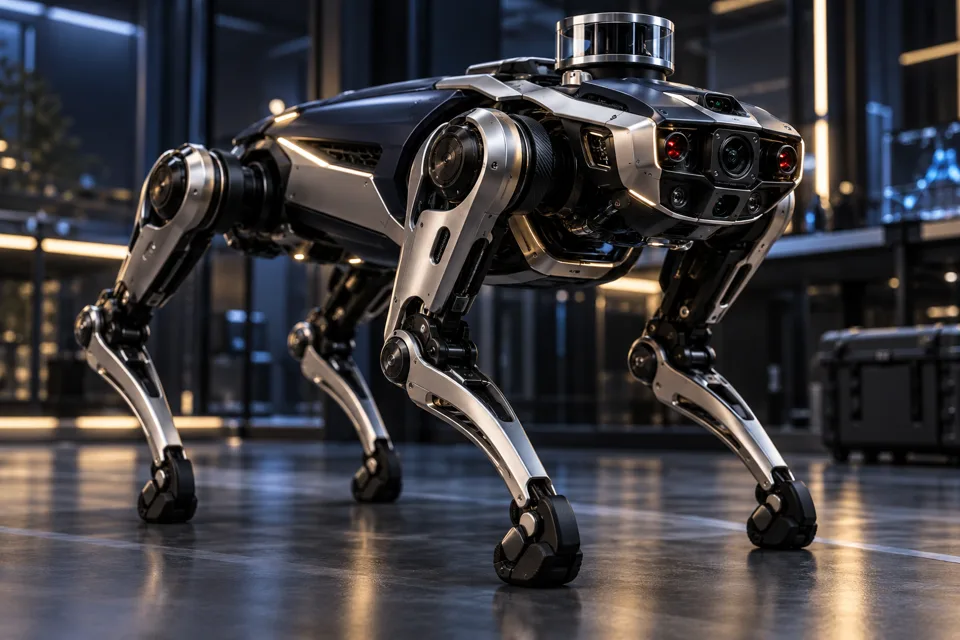
How does the robot know when its understanding is no longer good enough to act?
A model output becomes useful only within a larger decision loop. Define what the robot observes, how state is updated, what the planner may assume and which actions the control layer can execute.
Make uncertainty and stale information part of the design. An obscured sensor, an outdated map or a delayed state update can change the meaning of an otherwise plausible plan. The operating boundary should describe when to slow down, stop or ask for help.
Recovery deserves the same attention as the nominal mission. Consider a blocked route, a lost target and a restart after interruption. The architecture should explain who or what owns the transition back to a known condition.
For legged robots, examine the interaction between perception, locomotion and the operating environment. Humanoids and quadrupeds bring different reach, contact, balance and mobility constraints; the mission and test conditions should make those distinctions explicit.
What to take forward
- Sensing-to-action boundaries
- Uncertainty and stale-state handling
- Recovery and human intervention paths
What should I bring to a conversation?
Bring the decision you need to make, the constraints you already know and a small, non-confidential example. We can then agree whether a resource, a focused review or a more detailed discussion is the right next step.